ALBUM

Performing BOT

3 tracks, 8 min

Role

Designer · Developer

Team

Design · Dev

Made with

C++ · Arduino IDE · ElevenLabs

TRACK 00 · PROJECT BRIEF

We were tasked on building an animatronic robot made from cardboard, to perform on live stage, an over-the-top drama about a scandalous divorce court trial. Our team was assigned the role of the "Best Friend" – a double-crosser who betrays the wife by engaging in a secret affair with the husband.

Defining the Character Concept

We were thinking of an over-exaggerated "Malibu girl" trope, with a dramatically proportioned body, long acrylics, flashing outfit in pop colors, and big, puffed-up hair. We ultimately decided on a simpler design to reflect her shallow, air-headed personality.


SIGNATURE MANNERISMS

  • Sassy hip twists

  • Hair flips

  • T-rex arms with acrylics clacking

TRACK 01 · FABRICATION

Multiple different lip size swatches to avoid back-and-forth trips to the printer.

Multiple different lip size swatches to avoid back-and-forth trips to the printer.

Getting the receiver and transmitter to communicate. Turns out the problem was backwards wiring—an easy fix that has us floundering with code for many hours.

Getting the receiver and transmitter to communicate. Turns out the problem was backwards wiring—an easy fix that has us floundering with code for many hours.

Fiddling with the waist motor, trying to mark screw positions...

Fiddling with the waist motor, trying to mark screw positions...

Final Performance Complete!
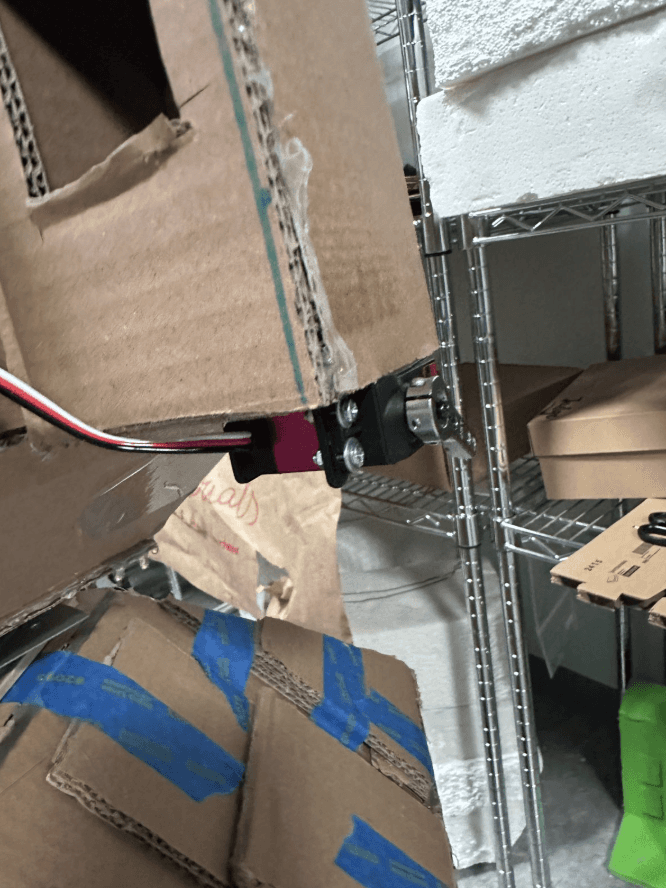
Final Performance Complete!

Testing code on the newly added elbow motor. Yay, it moved!
Testing code on the newly added elbow motor. Yay, it moved!

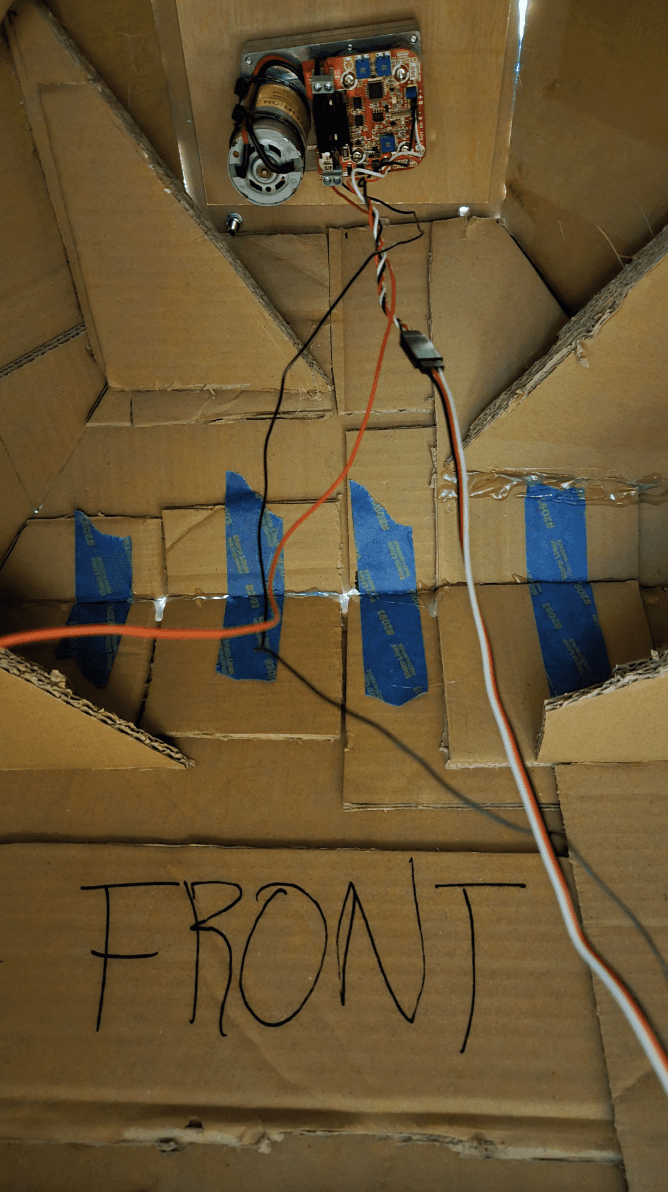
Inside of the lower body where the waist motor is attached.

Inside of the lower body where the waist motor is attached.

Soldering loose wire onto back of LED strips. A very finicky process requiring multiple redos...

Soldering loose wire onto back of LED strips. A very finicky process requiring multiple redos...

Adding right-angled gussets from scrap cardboard to strengthen internal structure of lower body.

Adding right-angled gussets from scrap cardboard to strengthen internal structure of lower body.

Securing the lower body onto the wheel base using an L-bridge.

Securing the lower body onto the wheel base using an L-bridge.

Adding in LED strips to the head for eyebrows! (lower strips: default eyebrow; upper strips: raised eyebrows)

Adding in LED strips to the head for eyebrows! (lower strips: default eyebrow; upper strips: raised eyebrows)

Day ??? of testing movement to soothe our anxieties about sudden malfunctioning of code —our greatest fear.

Day ??? of testing movement to soothe our anxieties about sudden malfunctioning of code —our greatest fear.

Building the forearms. Unsure where and how to attach the elbow motor but onwards we go!

Building the forearms. Unsure where and how to attach the elbow motor but onwards we go!

Arm falls off during rehearsal, 20 mins before the performance.
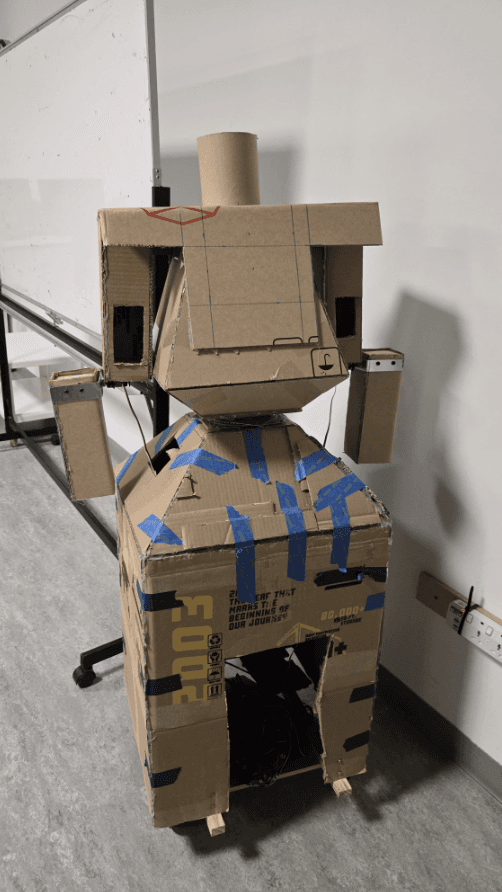
Arm falls off during rehearsal, 20 mins before the performance.

Milestone pic ❤️ Appreciating our handiwork. We’ve come a long way!

Milestone pic ❤️ Appreciating our handiwork. We’ve come a long way!

Adding  support beams onto the wheel base, all the while, cleaning up wires with cable ties.

Adding support beams onto the wheel base, all the while, cleaning up wires with cable ties.

Adjusting angles on code to achieve more natural movement.

Adjusting angles on code to achieve more natural movement.

Playing around with the costume. Very fancy~

Playing around with the costume. Very fancy~

Putting together reinforced cardboard panels to make the lower body.

Putting together reinforced cardboard panels to make the lower body.

Hand flap kept falling so made upgrades to secure these in place. Also testing movement to check if anymore changes needed to be made.
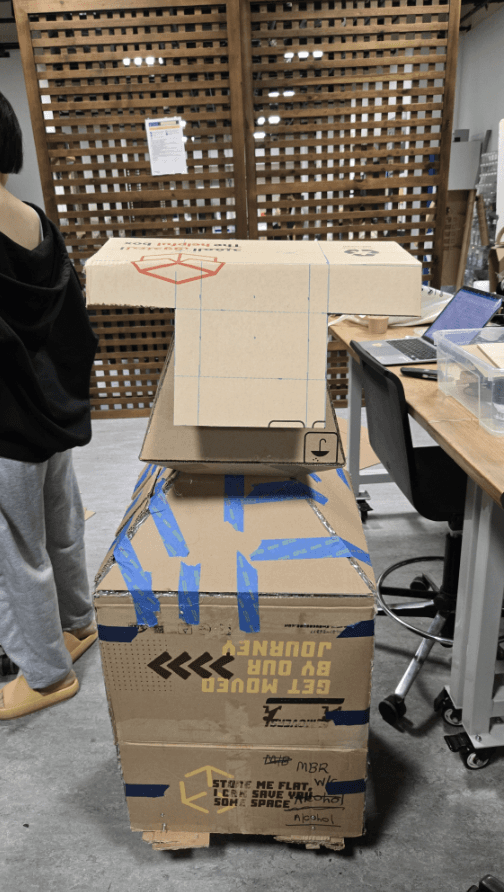
Hand flap kept falling so made upgrades to secure these in place. Also testing movement to check if anymore changes needed to be made.

Gluing shoulders onto the upper torso.

Gluing shoulders onto the upper torso.

Fabrication completed with 22 dialogue lines and unique accompanying actions!

To avoid repetition with key actions, we varied them for each line. For instance, a waist twist to express a needy demeanor, or one arm lifts to accent specific dialogue lines. We also introduced slight staggers to certain actions to make it's mannerisms look more human and natural.

TRACK 02 · CHALLENGES

TRACK 02 · CHALLENGES

Keeping track of all wiring and components

Our robot had a lot of components: 4 joint motors, a waist motor, 2 wheel motors, a receiver, and 4 LED strips, that we needed to keep track of. Our cable management quickly became overwhelming. Tracing loose or broken connections during hardware debugging was quite difficult as it meant we had to manually trace every single wire to figure out the issue.

Building a complete a robot from scratch

Sometimes, our linear workflow caused a few problems. For example, we had closed off the lower body before mounting the waist motor, forcing us to cram ourselves inside to install the components (which with all the gussets was incredibly challenging).

Building a complete a robot from scratch

Sometimes, our linear workflow caused a few problems. For example, we had closed off the lower body before mounting the waist motor, forcing us to cram ourselves inside to install the components (which with all the gussets was incredibly challenging).

ALBUM

Performing BOT

3 tracks, 11 min

Role

Designer · Developer

Team

Design · Dev

Made with

C++ · Arduino IDE · ElevenLabs